Build journal
32 sessions and 92 h of work, written down right after each session. Oldest first, so you can read it like a story.
Research & parts
6 h 8 min across 2 sessions
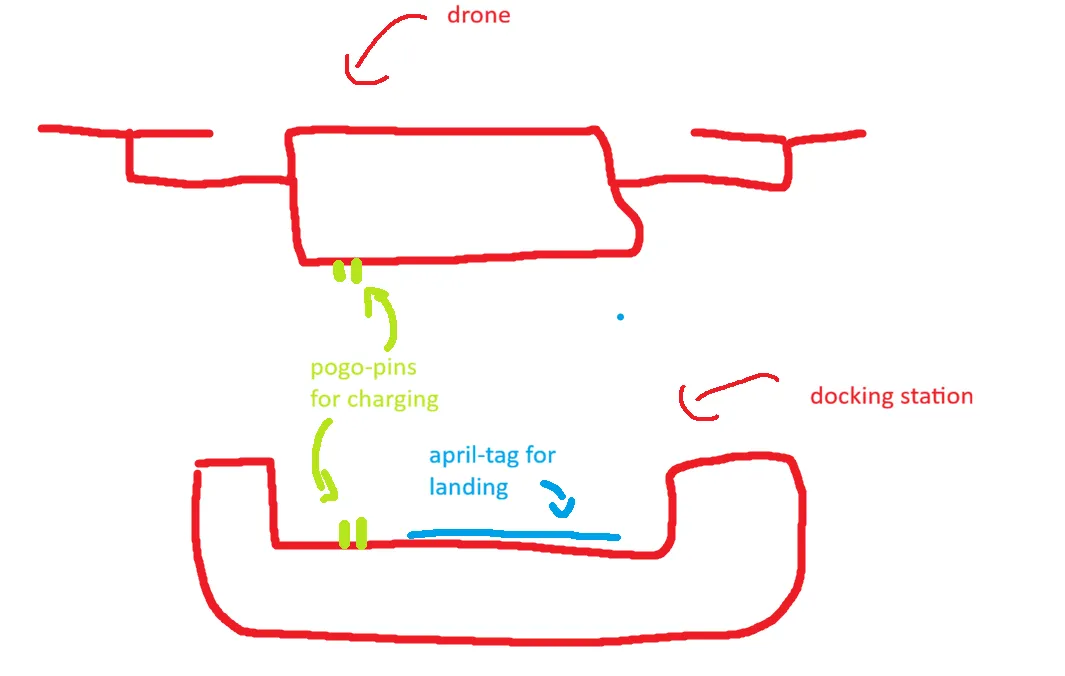
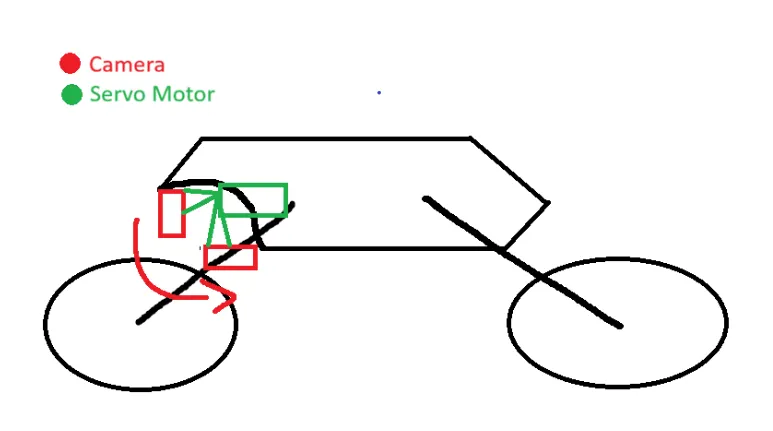
First sketches
1 h 15 min across 1 session
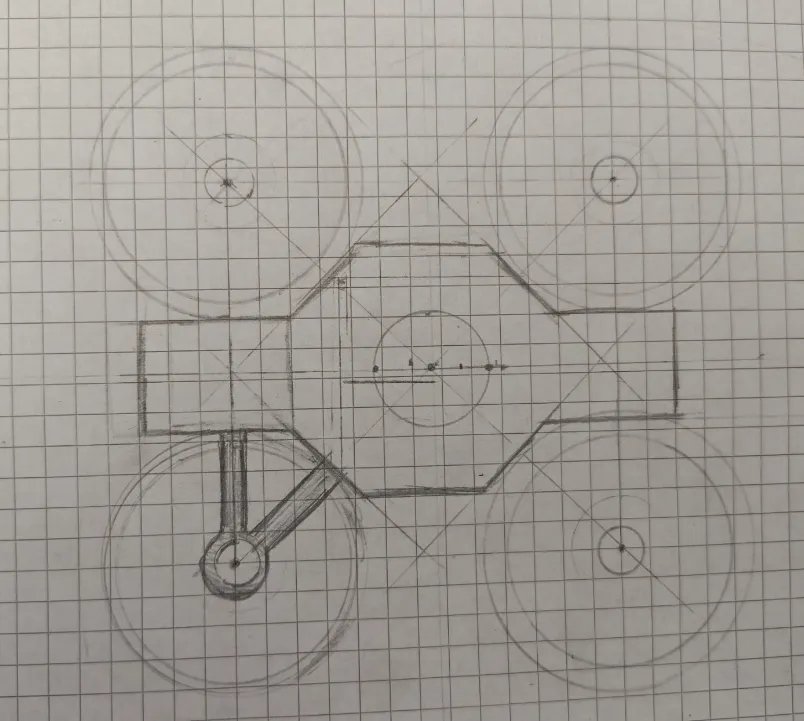
CAD design
31 h 57 min across 11 sessions
- 4CAD the motor base and arm!
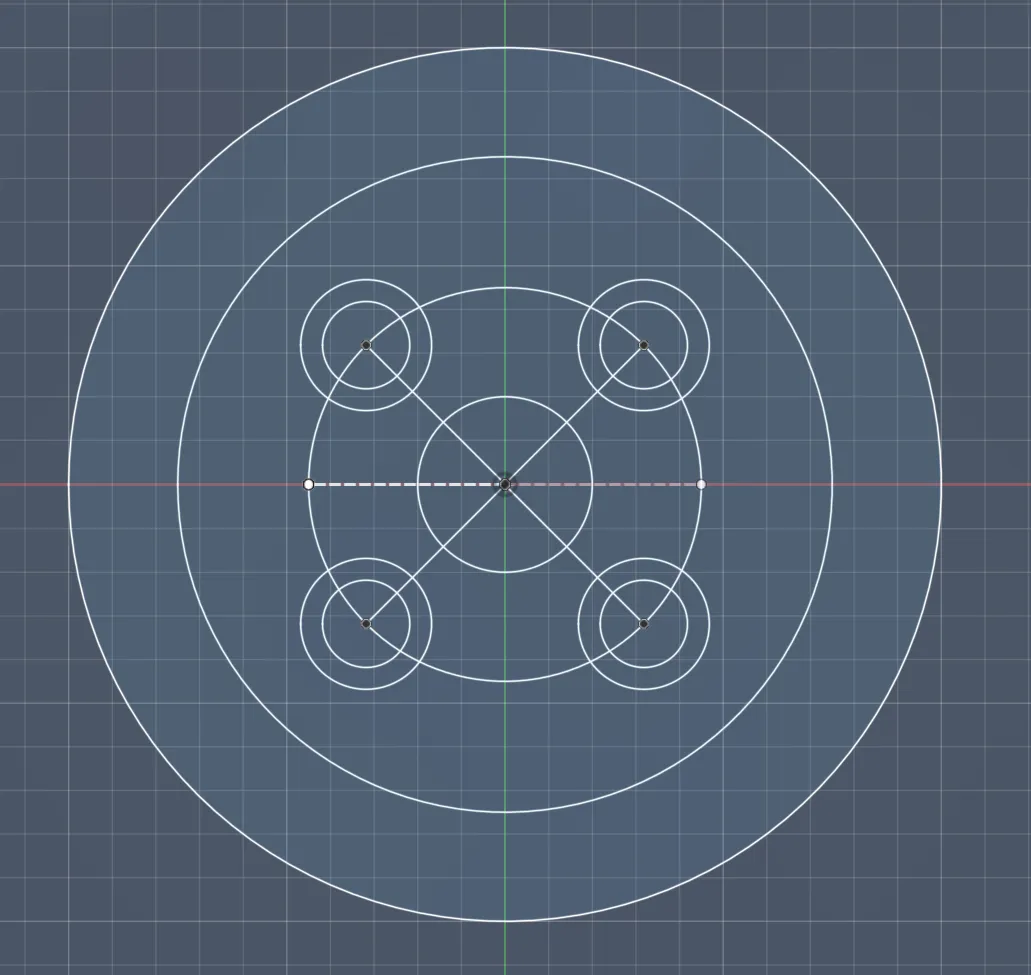
- 5Finished the Motor-Arm CAD design!
- 6Designing the base of the drone!!
- 7Finishing the arm holders and a TON of problems!
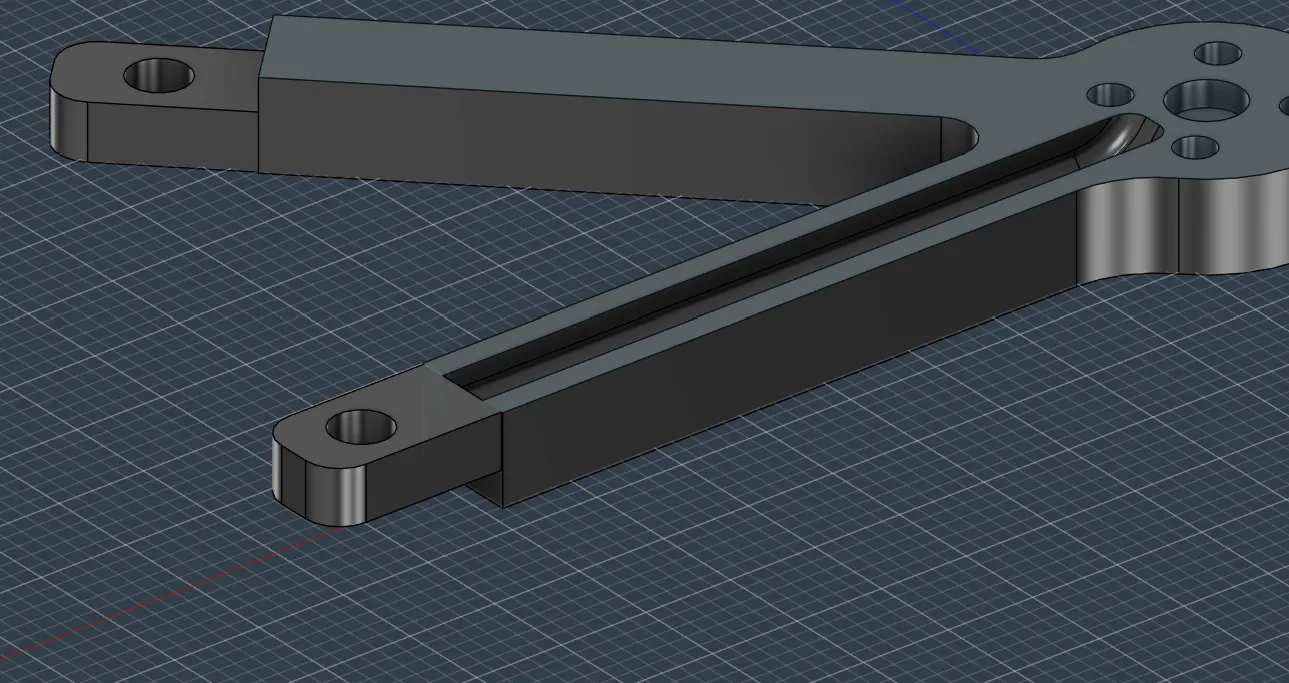
- 8Adding the combiner for the wall part and designing the small wall on the platform
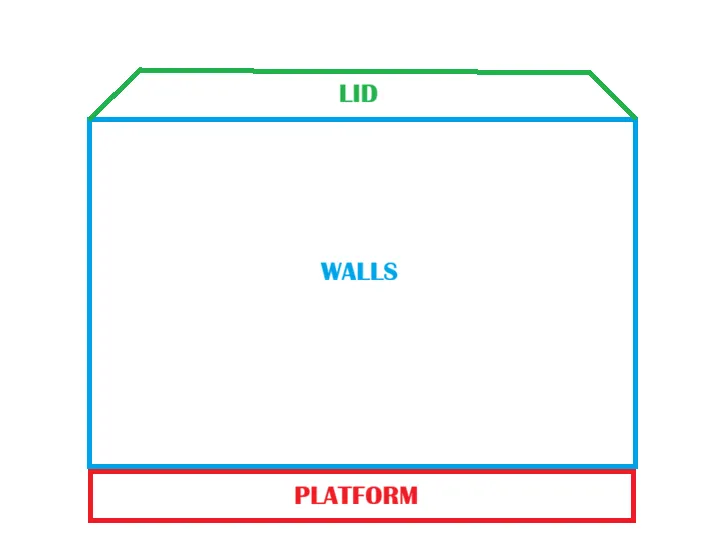
- 9Designing the connection to the walls and designing them!!!
- 10Finished the Main CAD design on the drone!!!
- 11Building the camera and servo mechanism
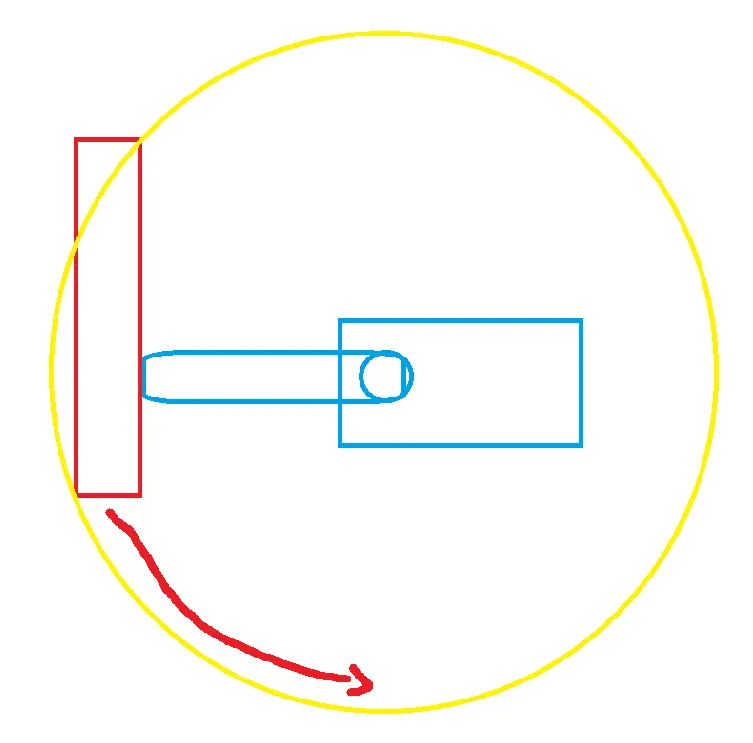
- 12Fixing some issues with the servo motor and FINALLY finishing it!
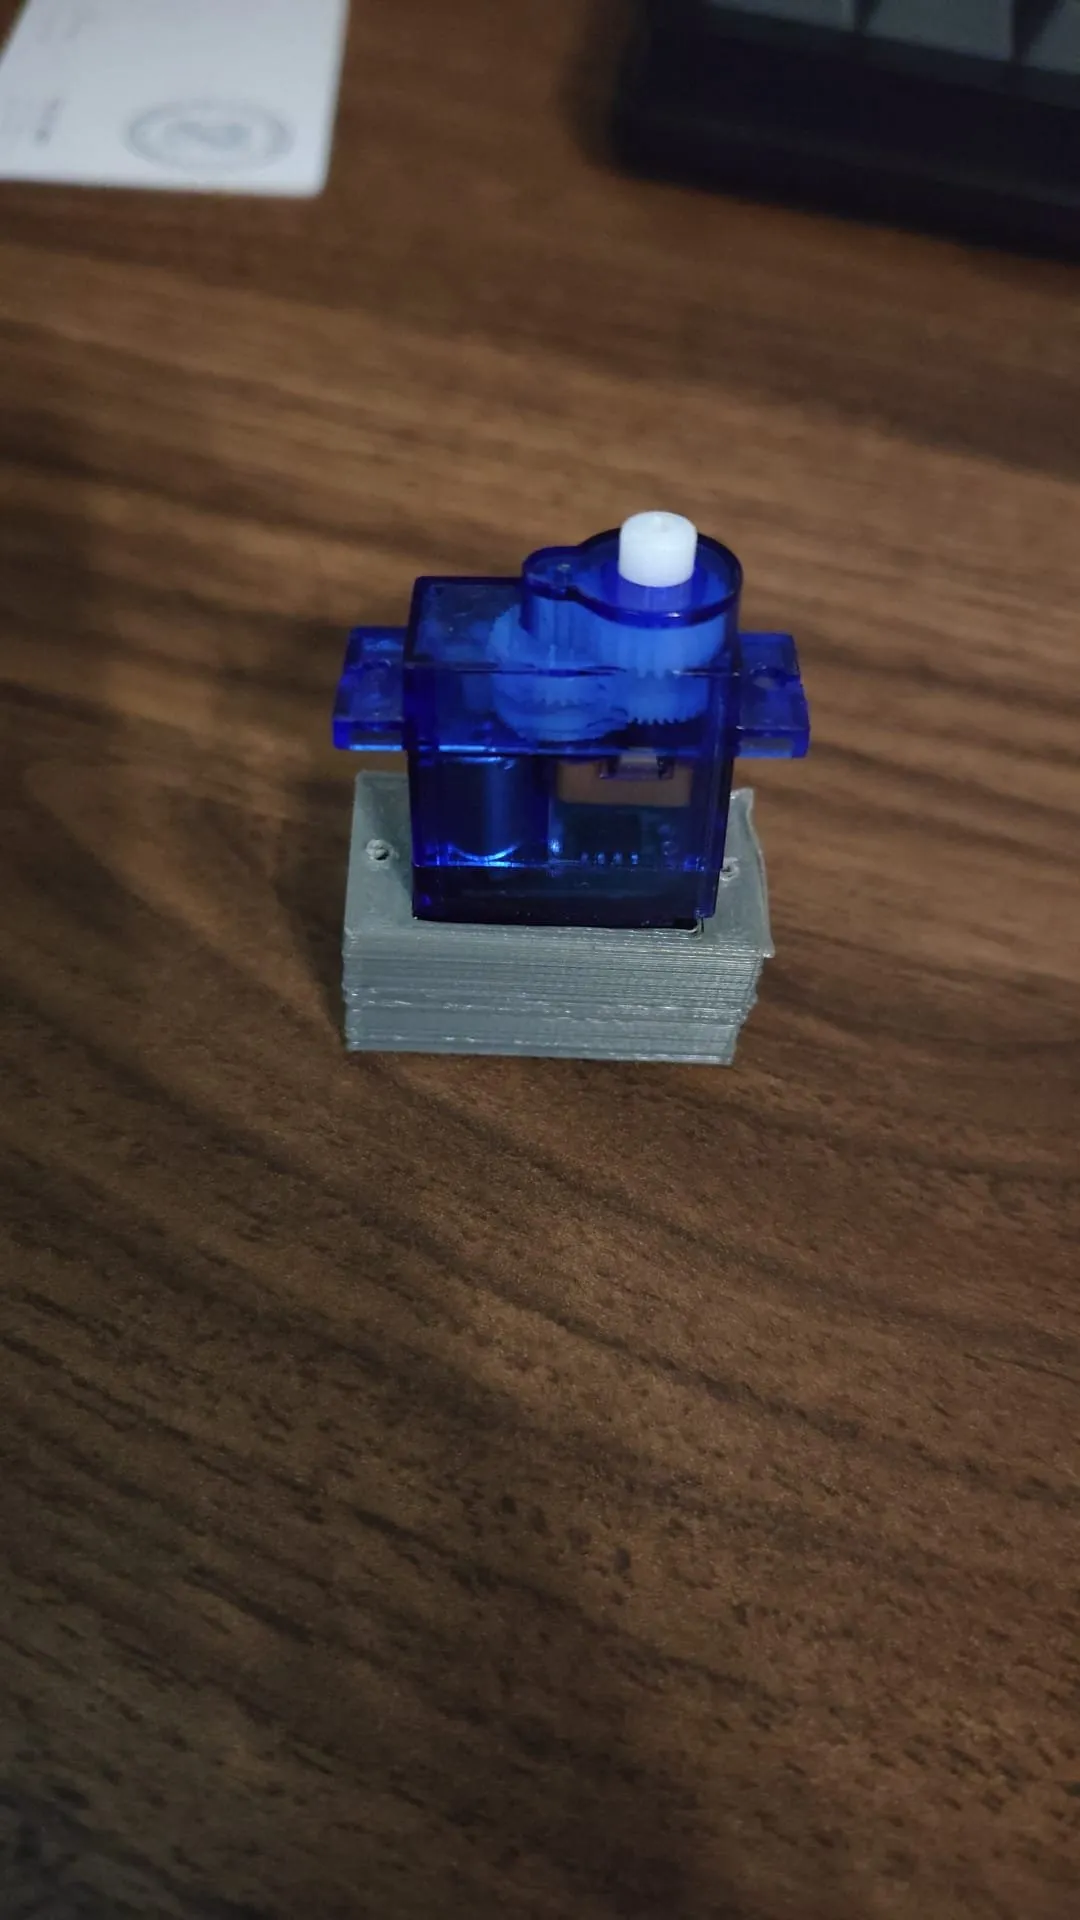
- 13Added the ToF-Sensors to the CAD Model and optimized it!
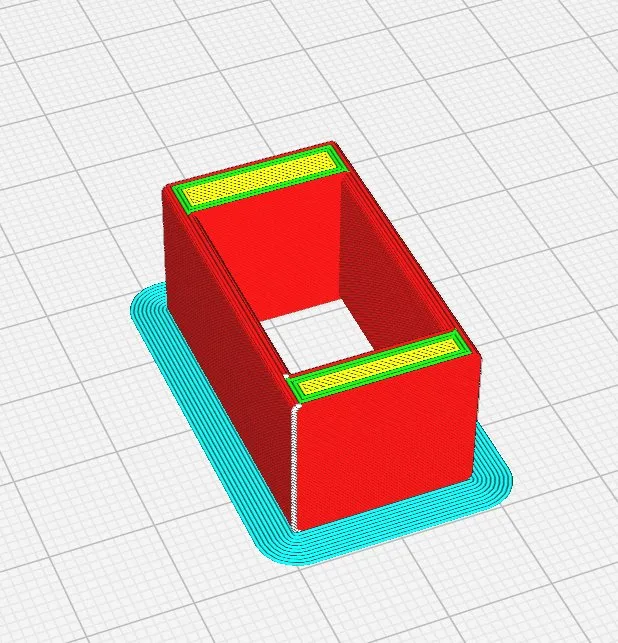
- 14Finishing the Drone CAD: adding the prop guards!
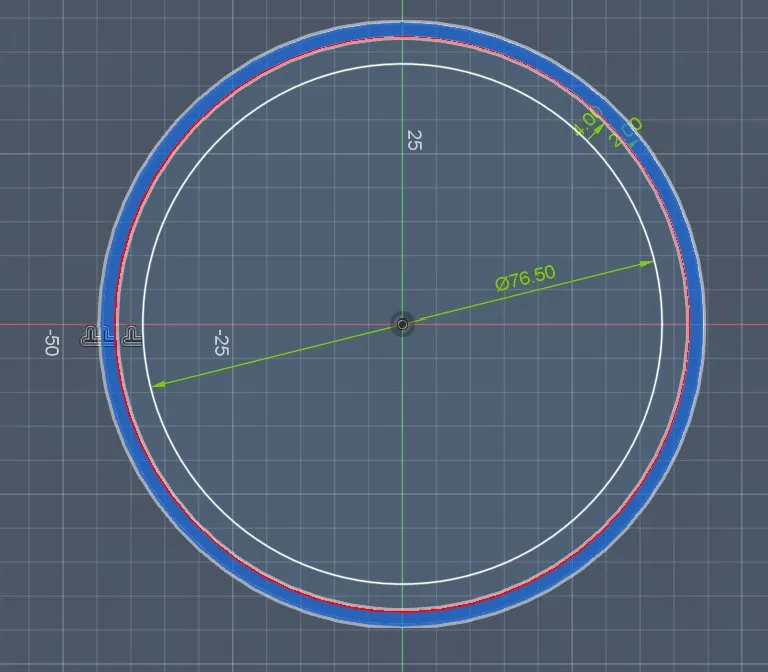
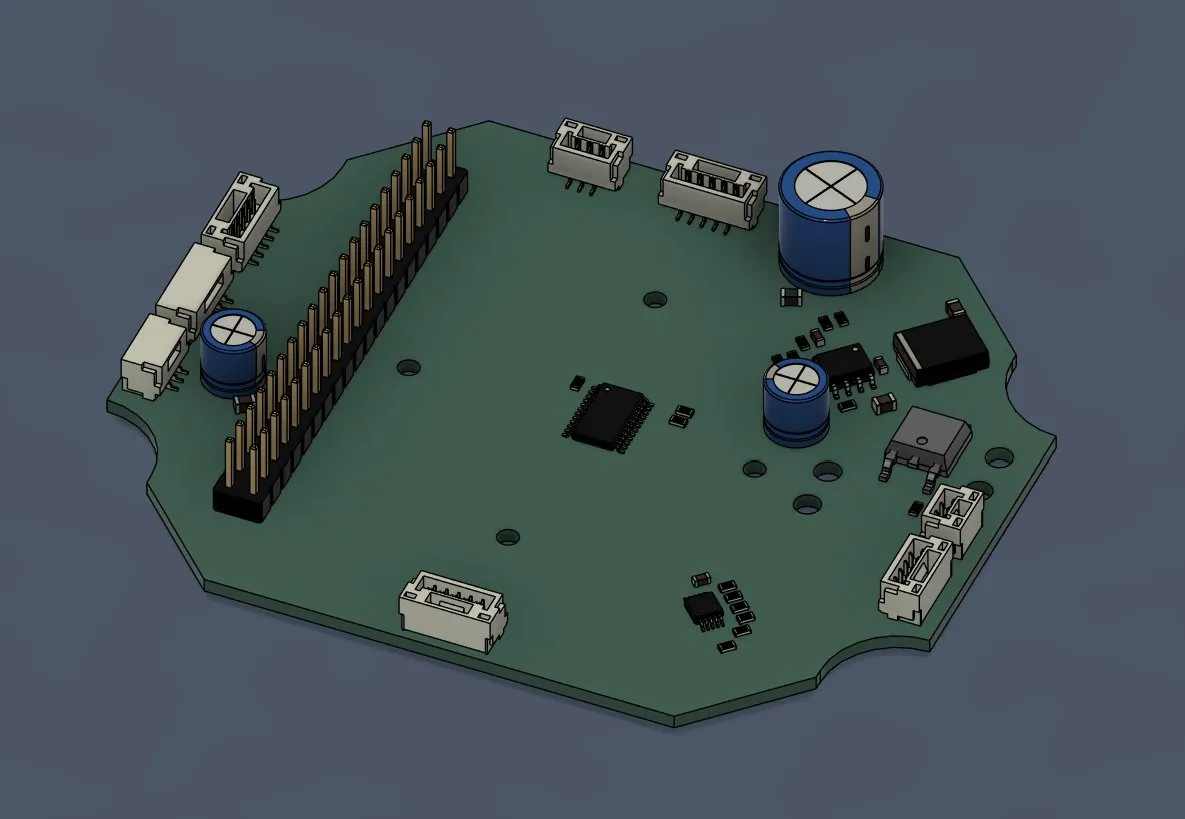
PCB design
30 h 50 min across 12 sessions
- 15Starting the PCB!!!
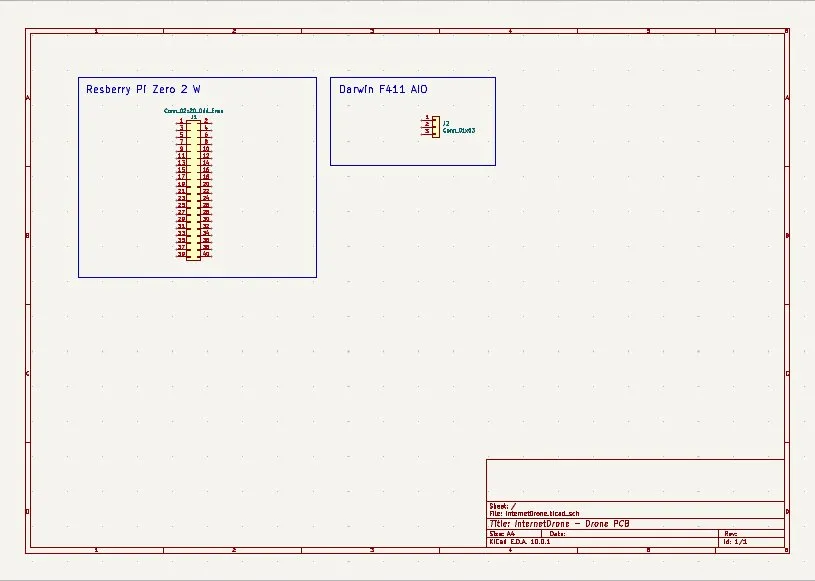
- 16Designed the MP1584 Buck Converter for the Raspberry Pi!
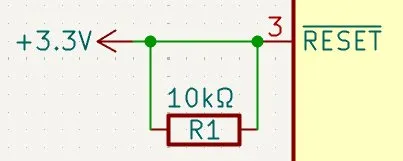
- 17Finished the Schematics of the PCB: charging mode etc!
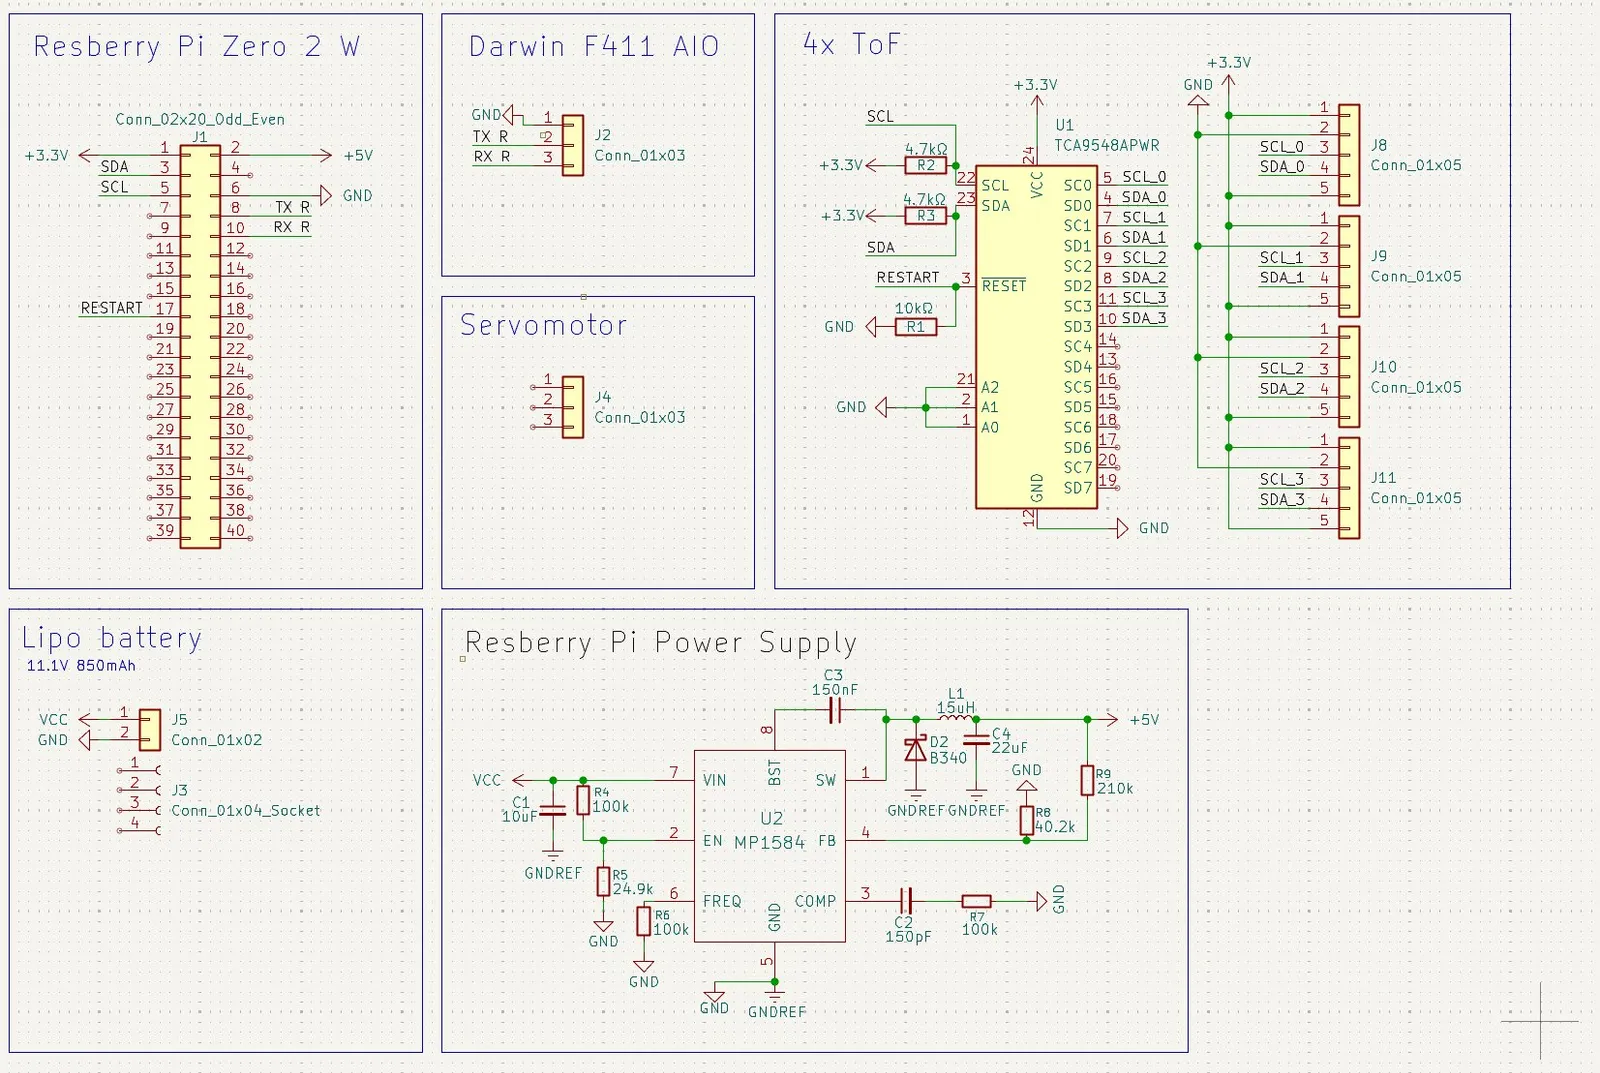
- 18Finished the schematics for my drone PCB!
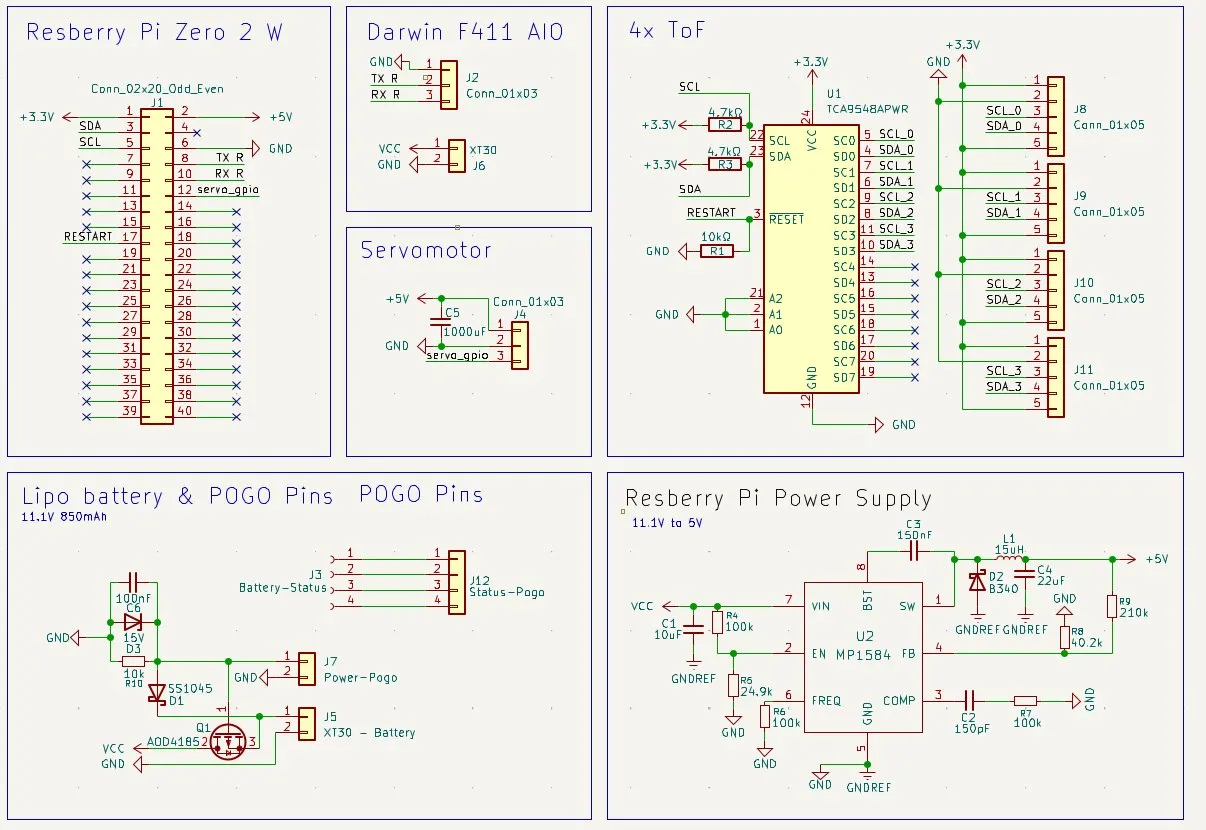
- 19Fixing schematics problems/errors and placing the components on the PCB!
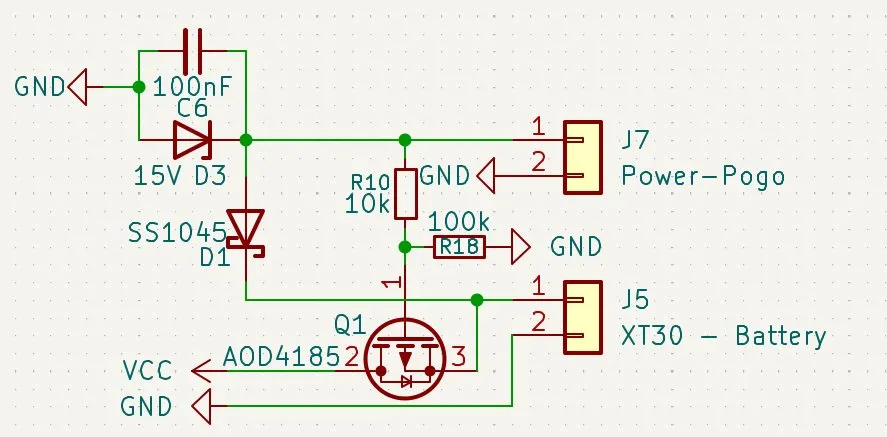
- 20Fixed last issue with schematics and started the routing!
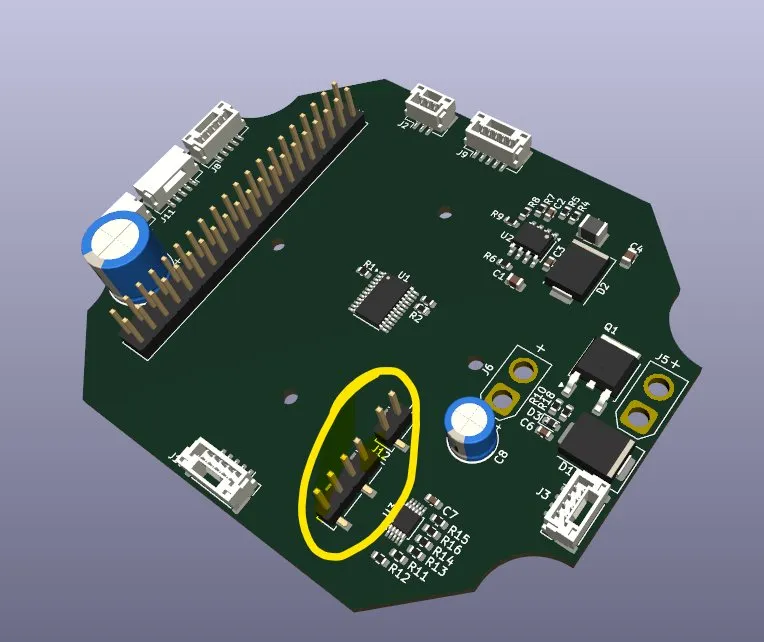
- 21Fixing last issues in the drone schematics!
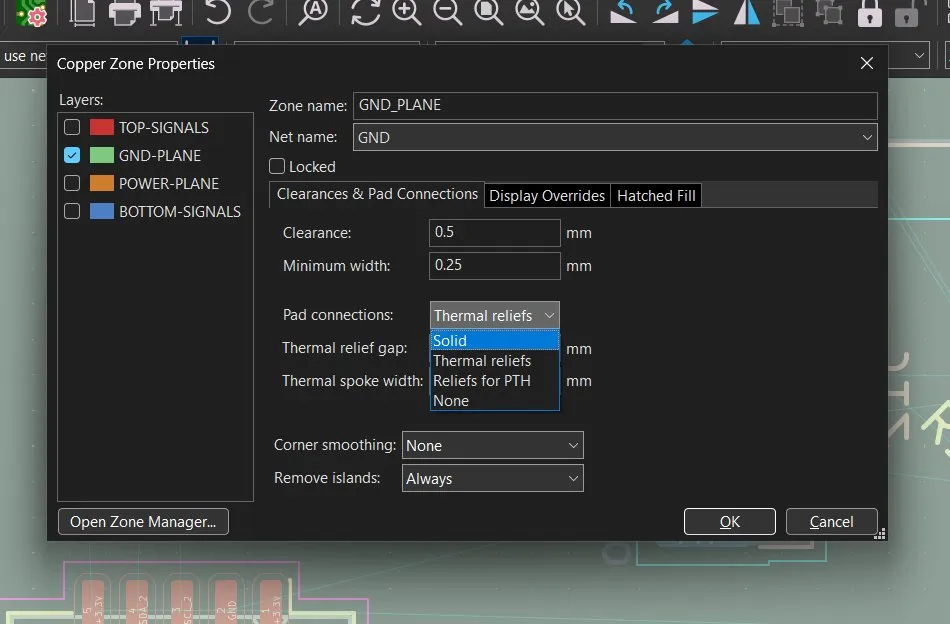
- 22Fixing the routing and starting again with it!
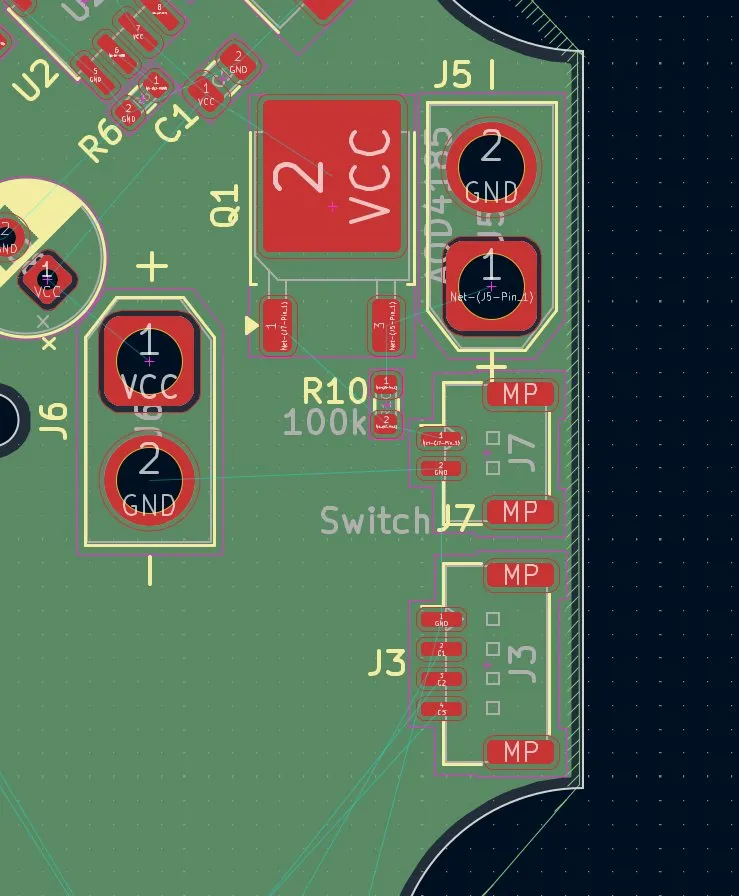
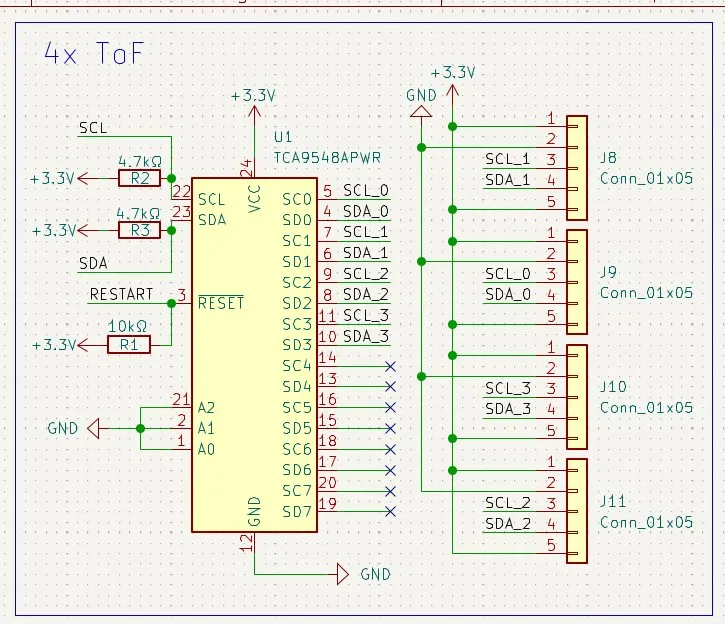
- 23Finished the battery percentage and started the sensor I2C connection!
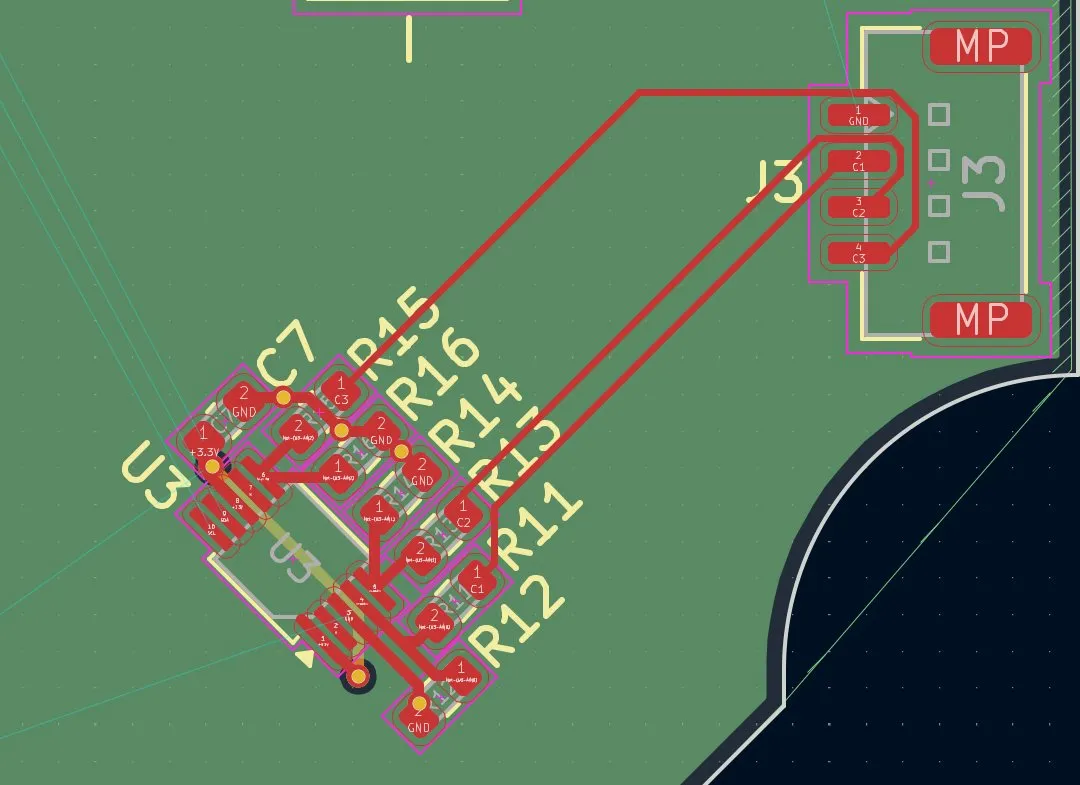
- 24Routing the 3.3V power supply and starting the 12.6V to 5V buck converter!
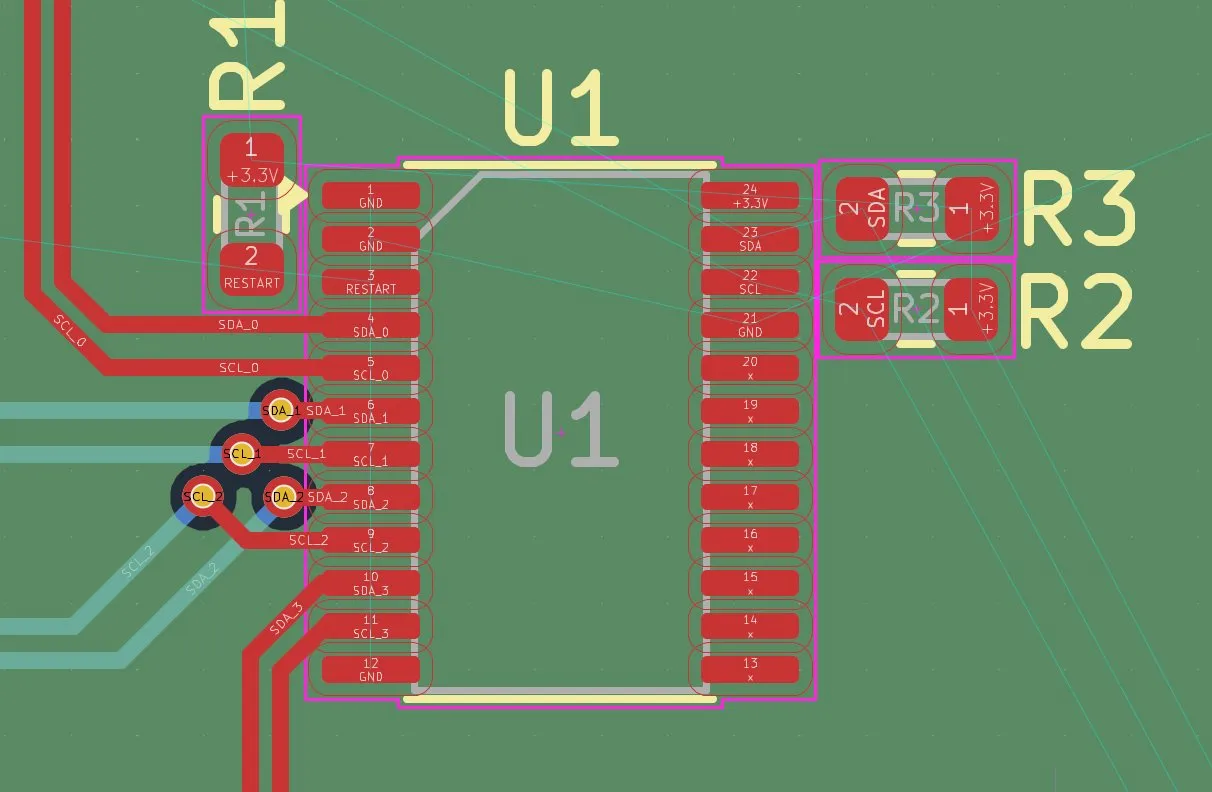
- 25FINISHED THE PCB!!!!
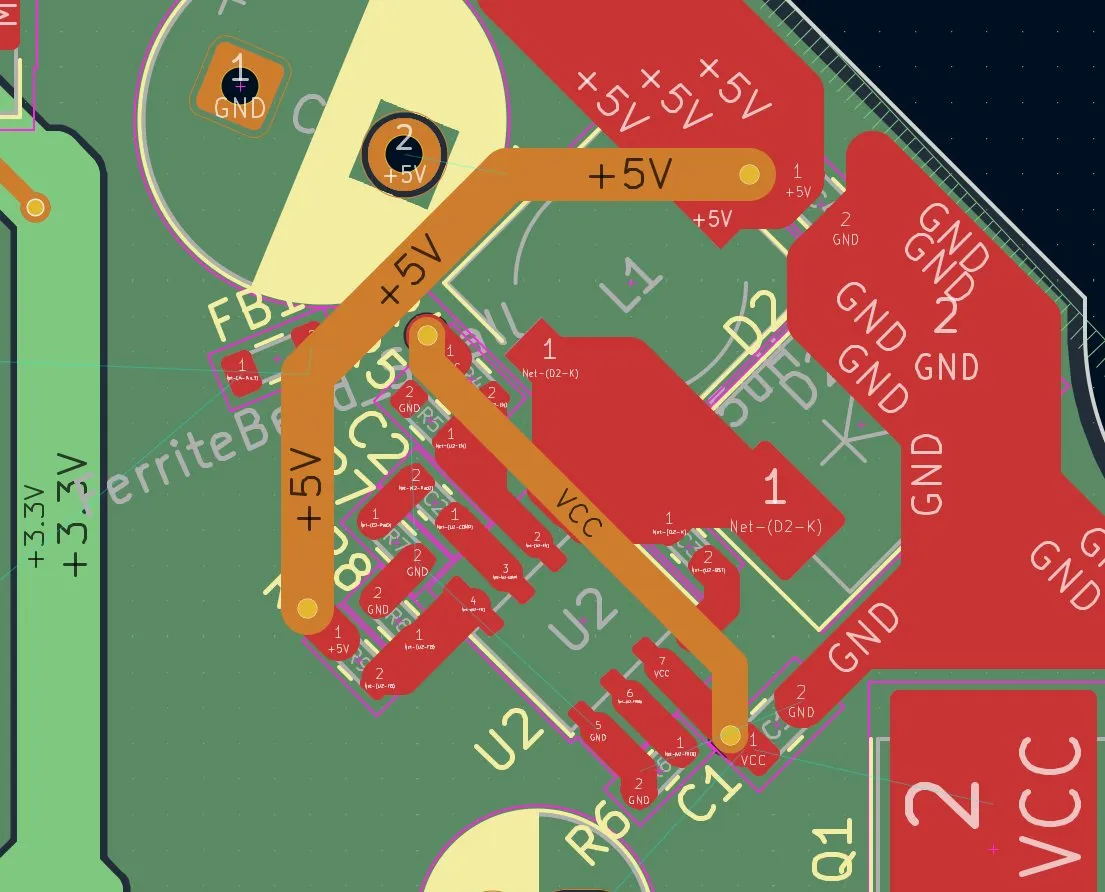
- 26Finding name and finishing the PCB!
Landing station
5 h 59 min across 1 session
Firmware & cockpit
11 h 28 min across 4 sessions
Documentation
4 h 23 min across 1 session